Engineering portfolio
Projects
Robotics, AI, biomedical engineering, leadership, and engineering coursework. Open a project for my contribution, original photographs, results, and demonstrations.
Robotics, AI, and Software
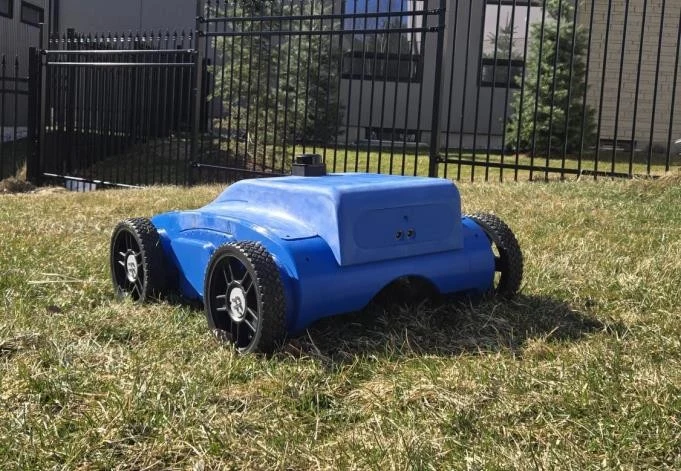
Autonomous lawn mower
A ROS-based autonomous mower combining YOLOv8 perception, LiDAR mapping, localization, coverage planning, motion control, and safety checks; my work spanned perception and autonomy integration.
AI & perception lead · mapping, planning and autonomy integration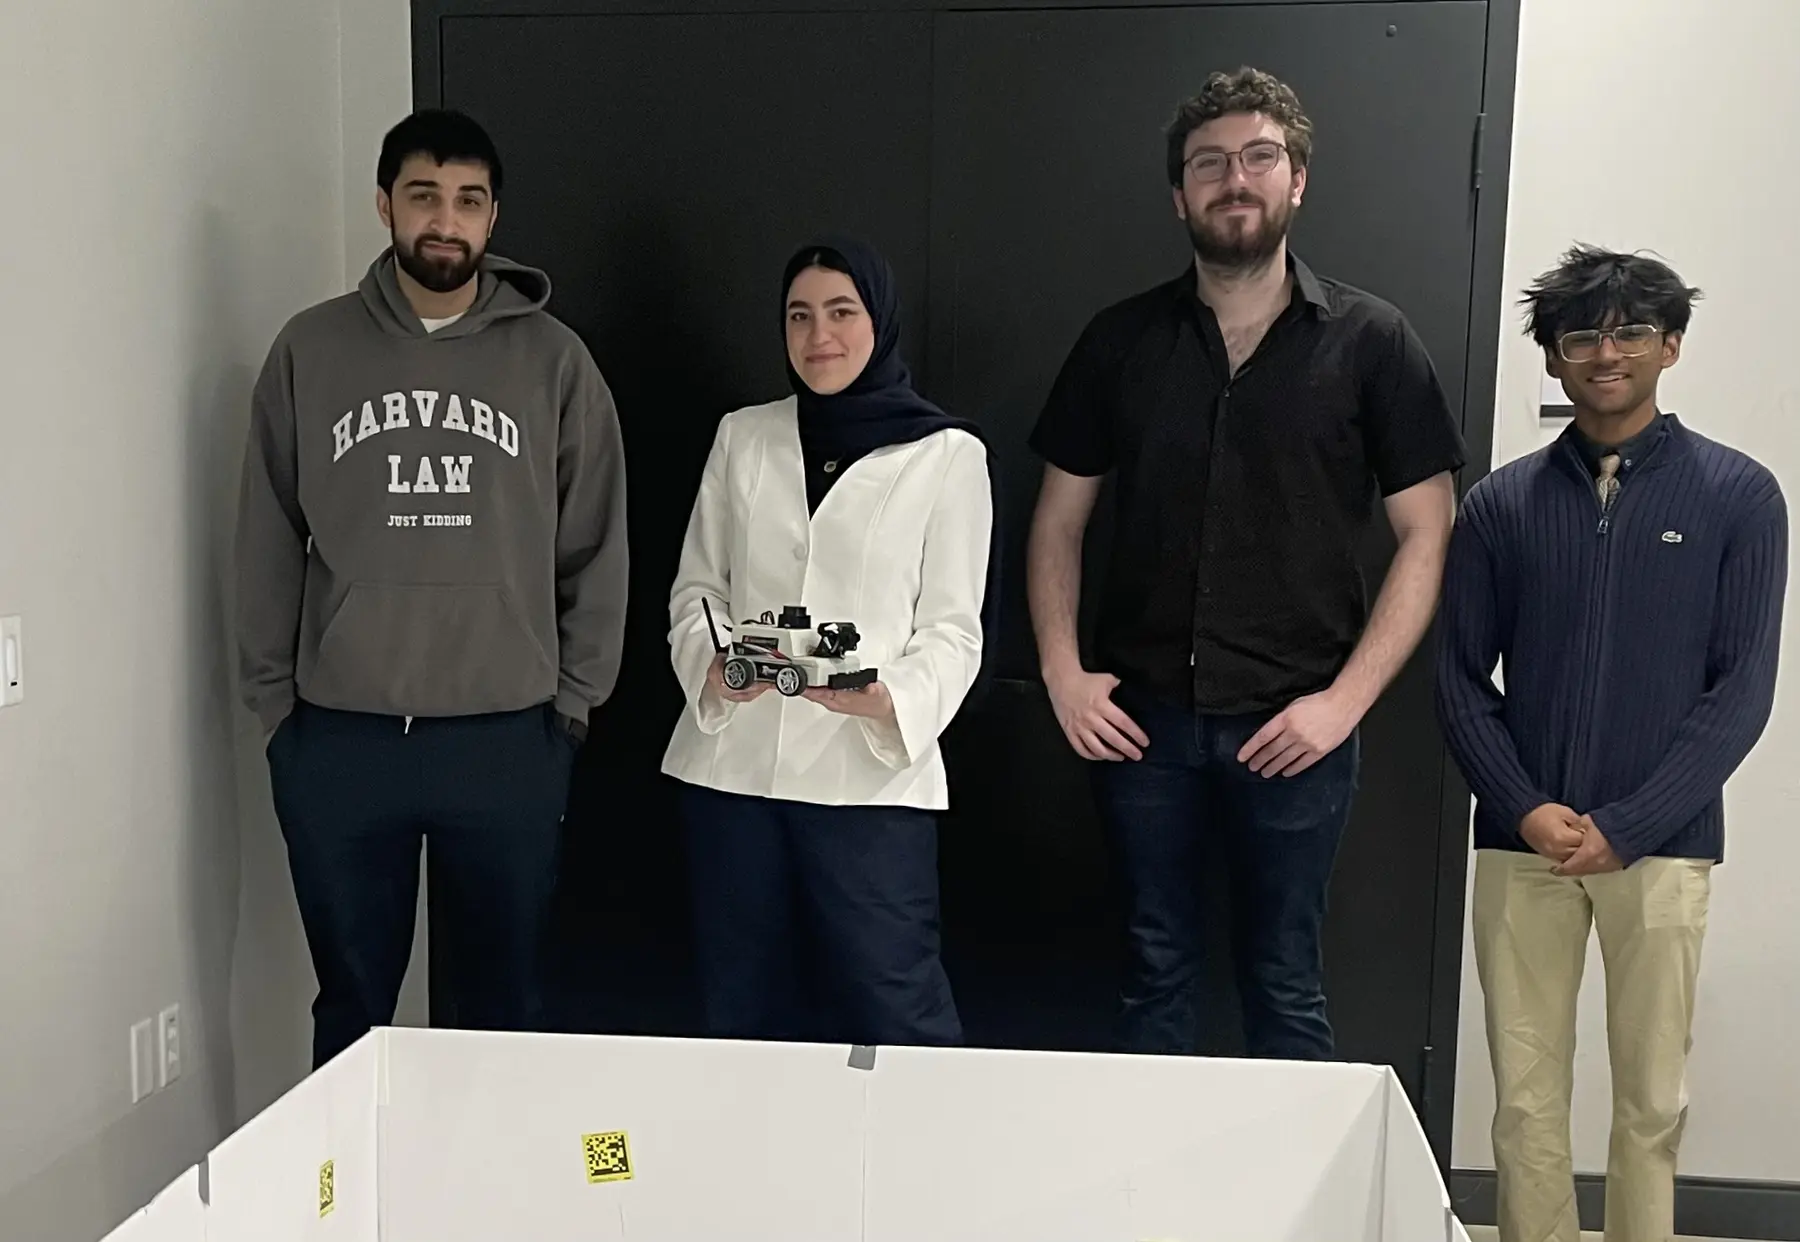
Smart wheelchair navigation
ROS 2 / Nav2 indoor robot navigation with LiDAR mapping, Python/OpenCV hazard detection, and pyzbar barcode arrival checks.
Team project · AISE 4020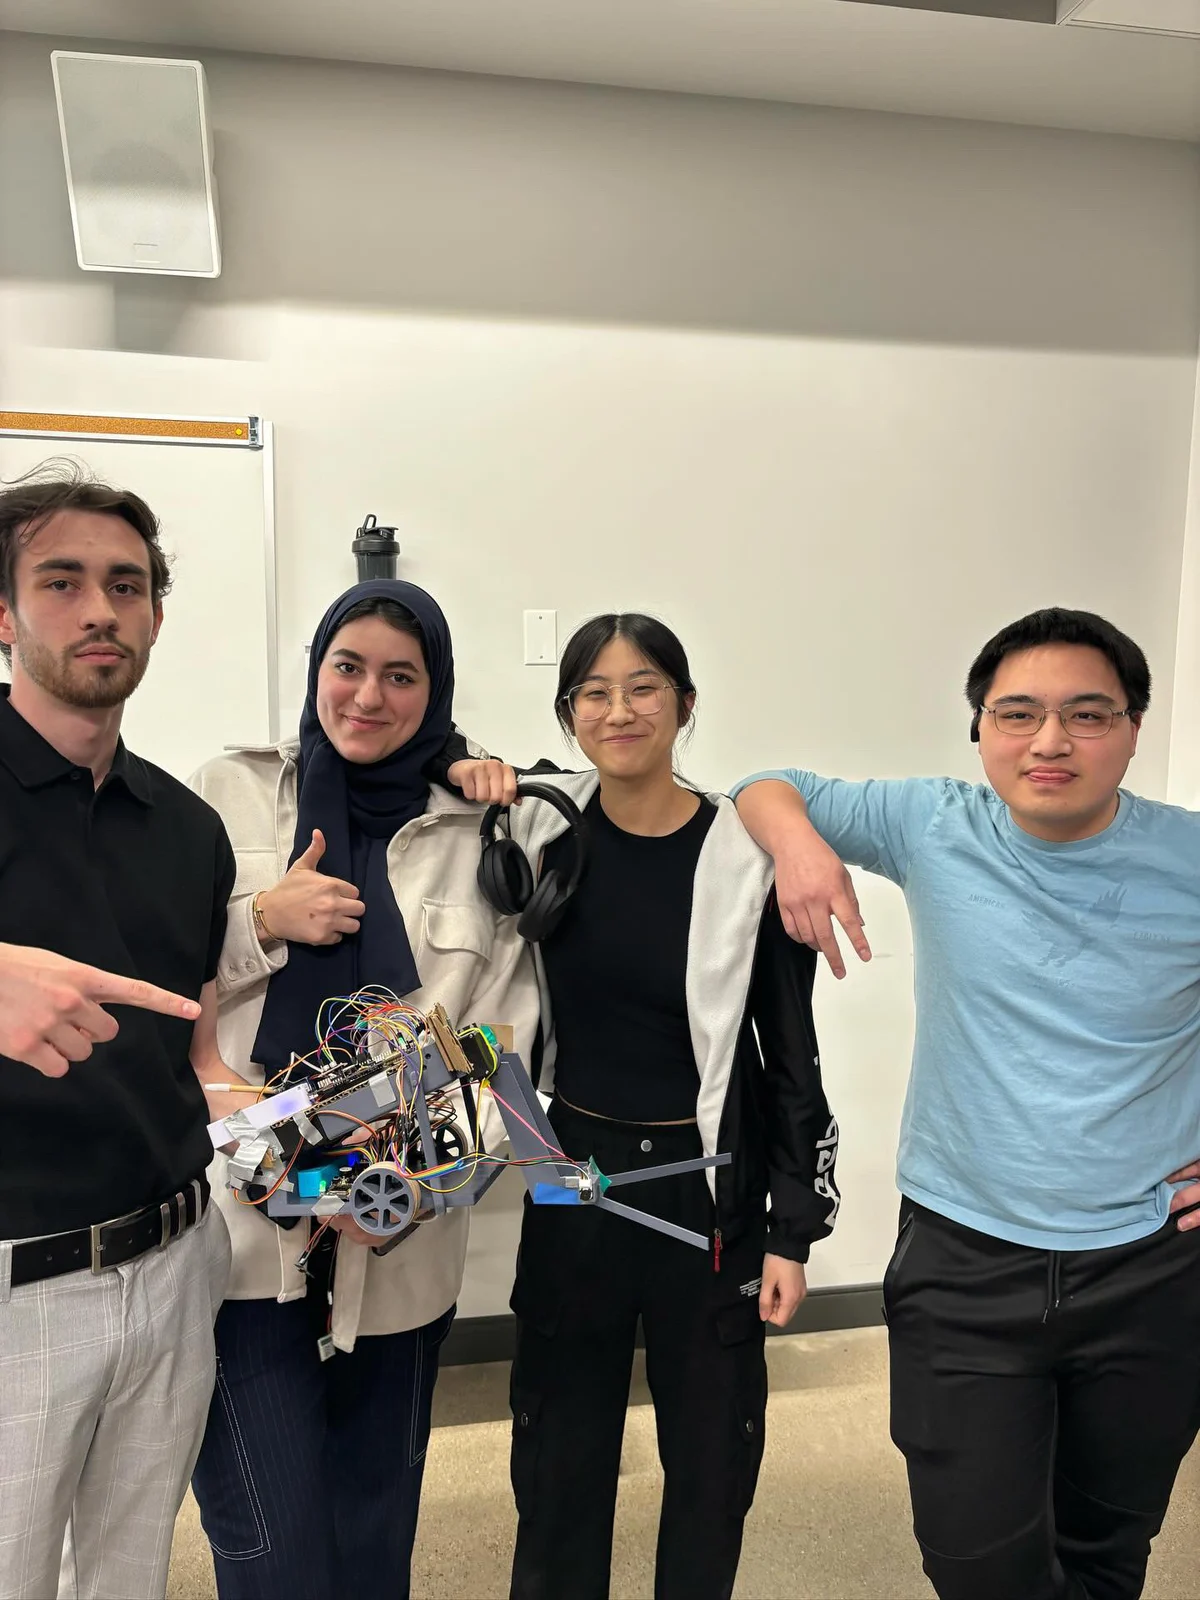
Gem-sorting rover — Scooper Bot 10001
An ESP32-S3 rover combining Arduino C++, PID wheel control, encoder feedback, TCS34725 color sensing, and 3D-printed sorting mechanisms.
Team project · MSE 2202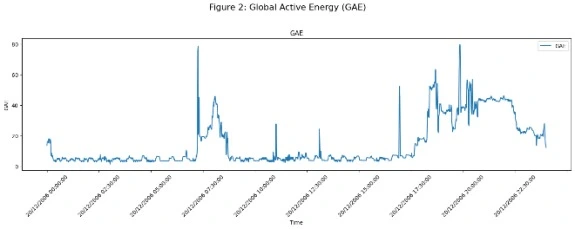
Household energy forecasting
TensorFlow/Keras LSTM forecasting of household electricity use, with pandas/NumPy preprocessing, engineered energy features, and time-series windowing.
Group project · preprocessing, features, and LSTM development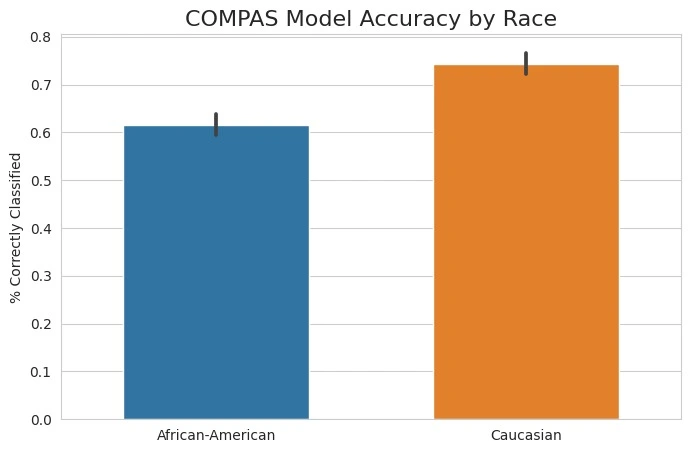
Machine-learning fairness and differential privacy
Python coursework using AIF360, fairlearn, DoWhy, diffprivlib, TensorFlow, and scikit-learn to investigate fairness, causality, and privacy tradeoffs.
Individual fairness, causality and privacy investigations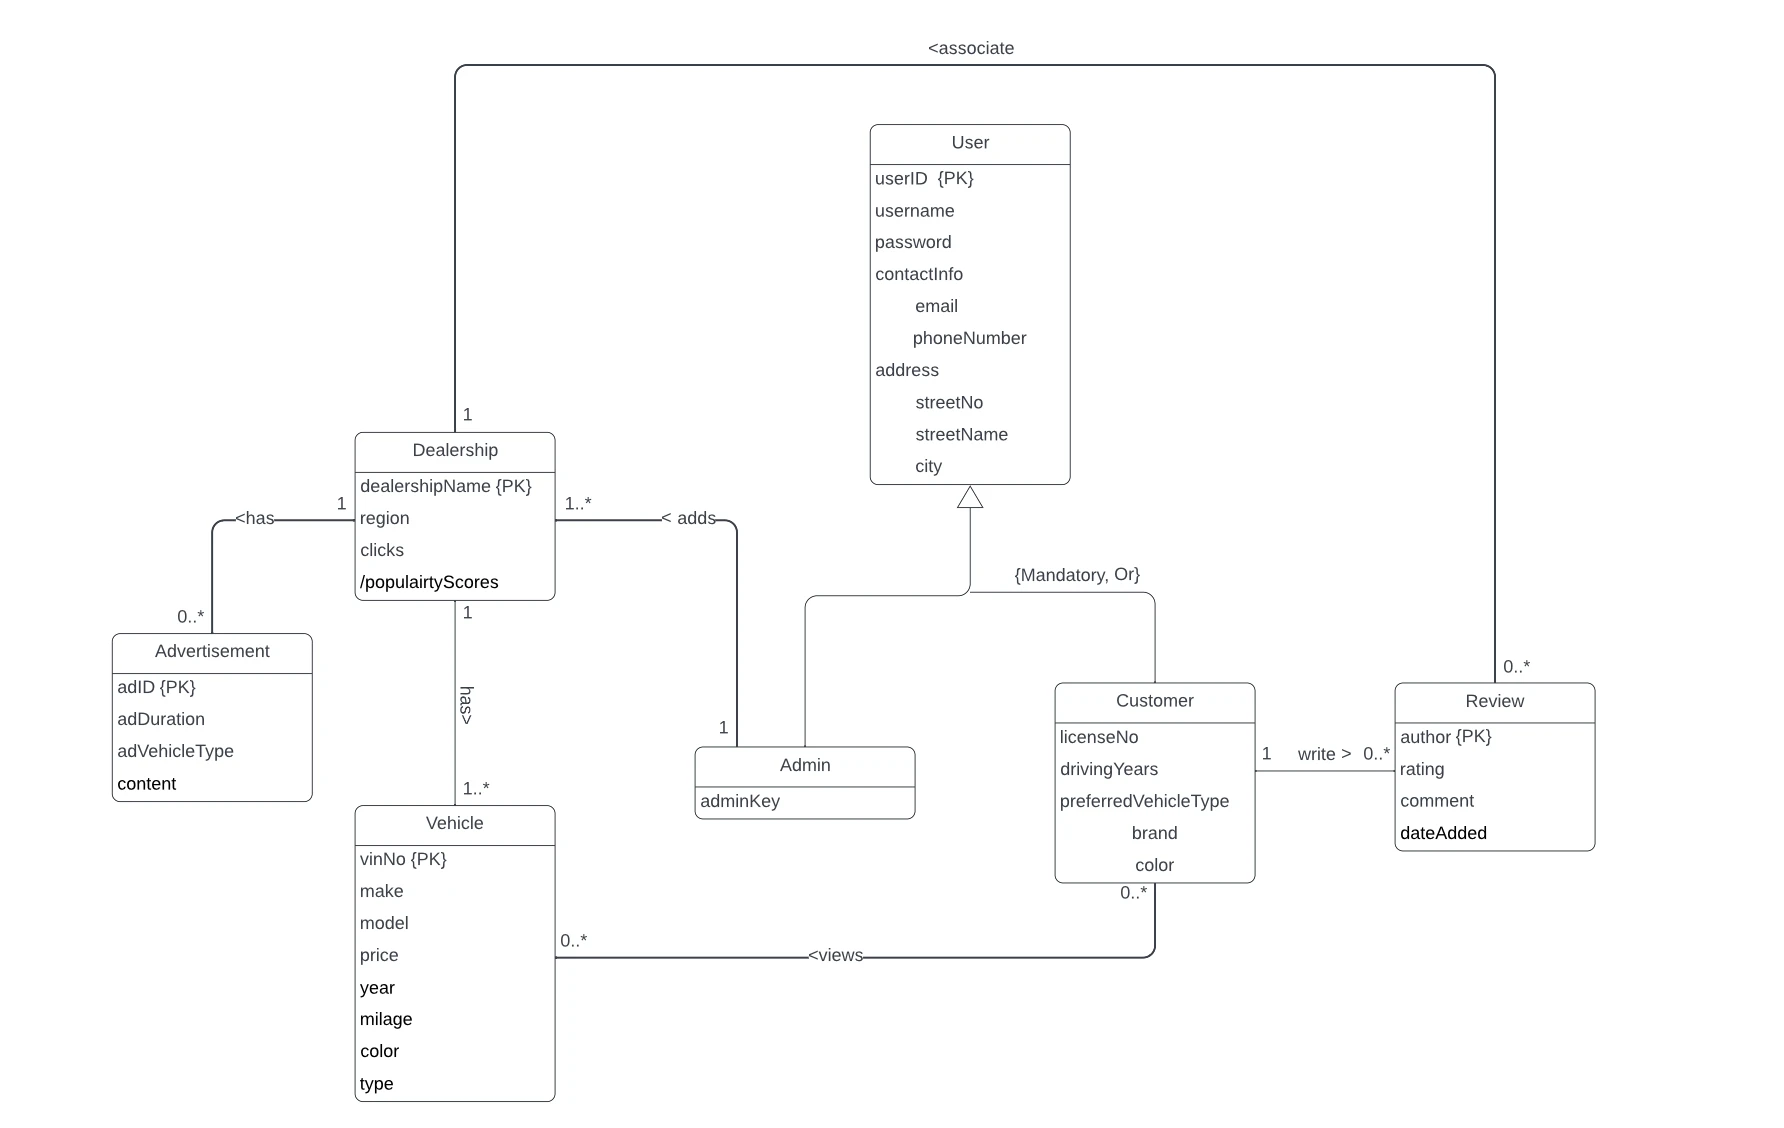
C.A.R. vehicle marketplace database
A MySQL vehicle-marketplace database with ER modeling, relational constraints, SQL queries and views, and a React/Next.js web application.
Team database project · requirements and functionality specification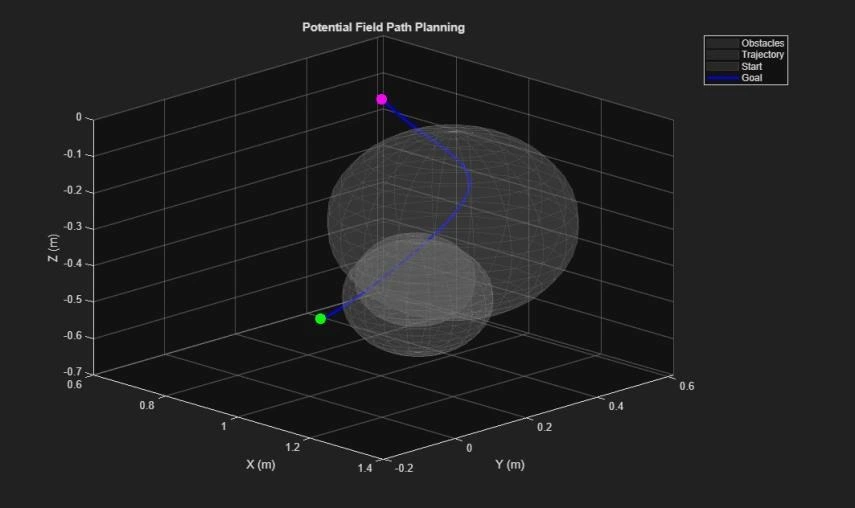
Six-axis robot arm kinematics and path planning
MATLAB kinematics and potential-field motion planning for a six-axis manipulator, using DH parameters, Jacobians, and obstacle-avoidance parameter sweeps.
Partner project · MSE 4401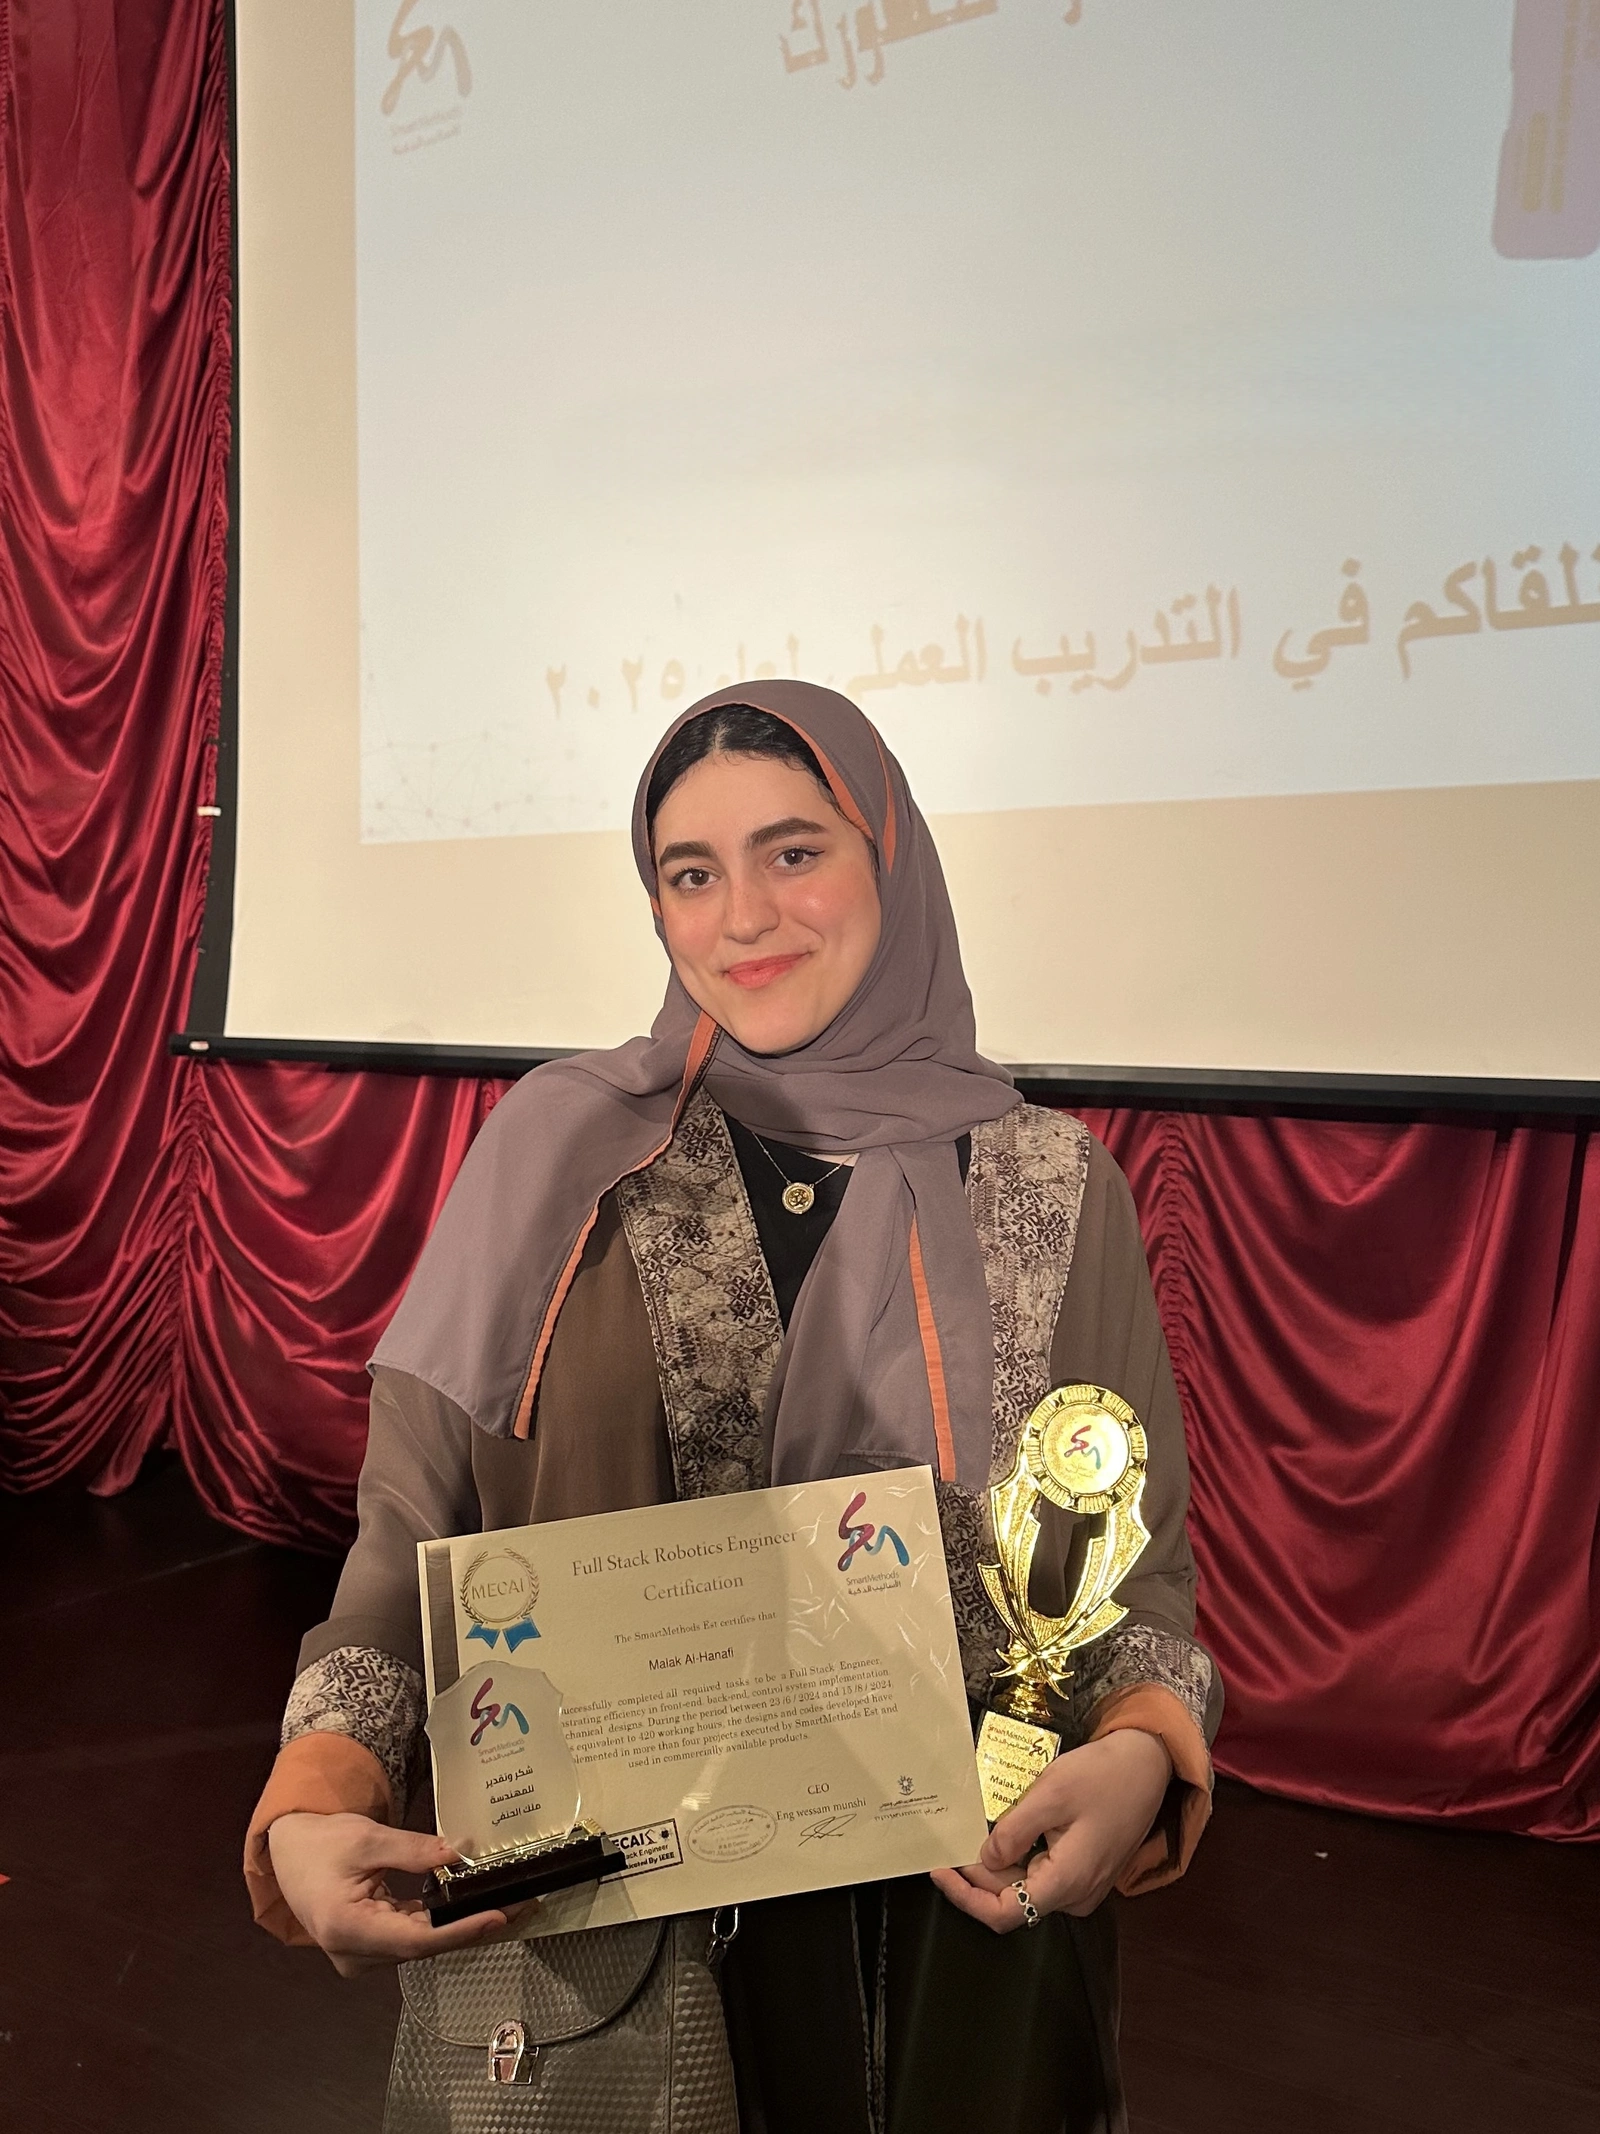
Smart Methods engineering internship
Smart Methods internship work spanning SolidWorks/STL fabrication, servo mechanisms, Python/OpenCV interfaces, JavaScript web work, and speech-to-text prototypes.
Smart Methods engineering internshipBiomedical engineering
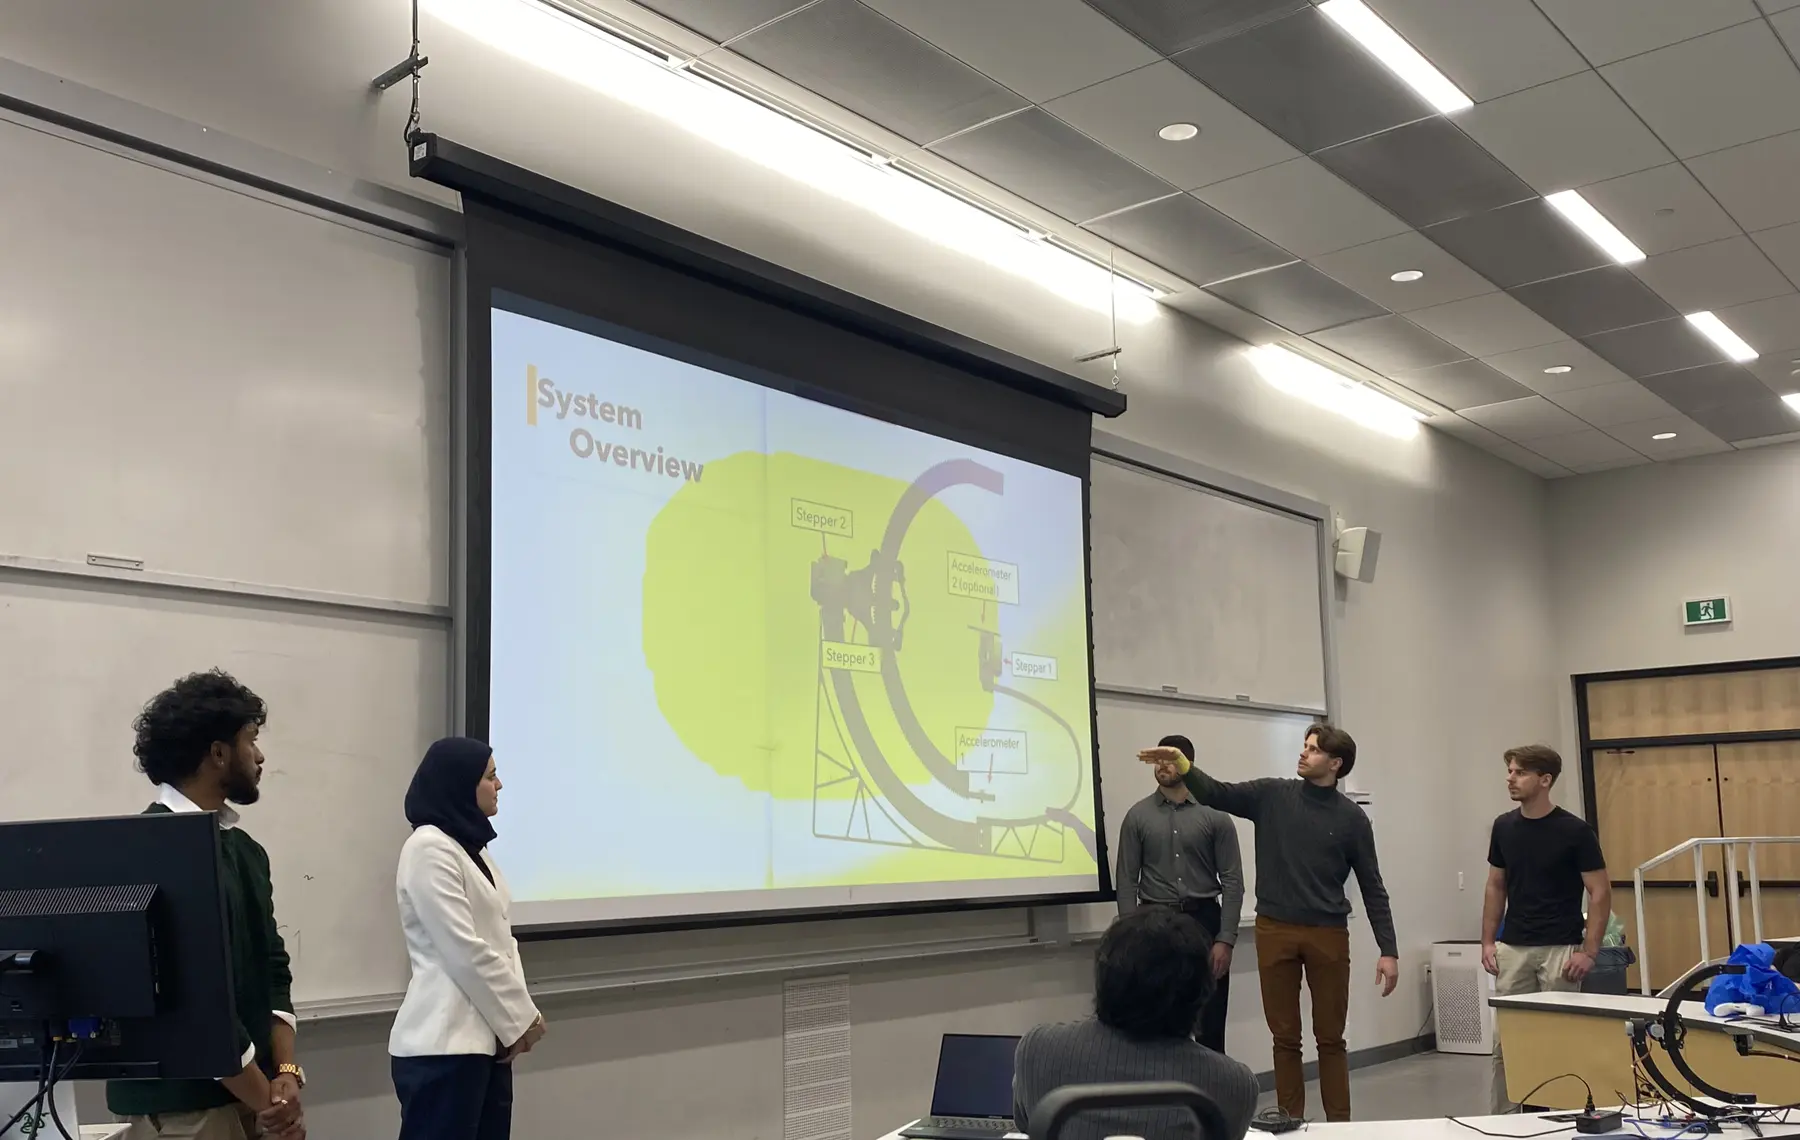
Miniature C-arm surgical simulator
A SolidWorks and PLA-printed C-arm prototype using Arduino C++, AccelStepper, A4988 motor drivers, and Bluetooth-to-3D Slicer integration.
Team project · sensors and actuators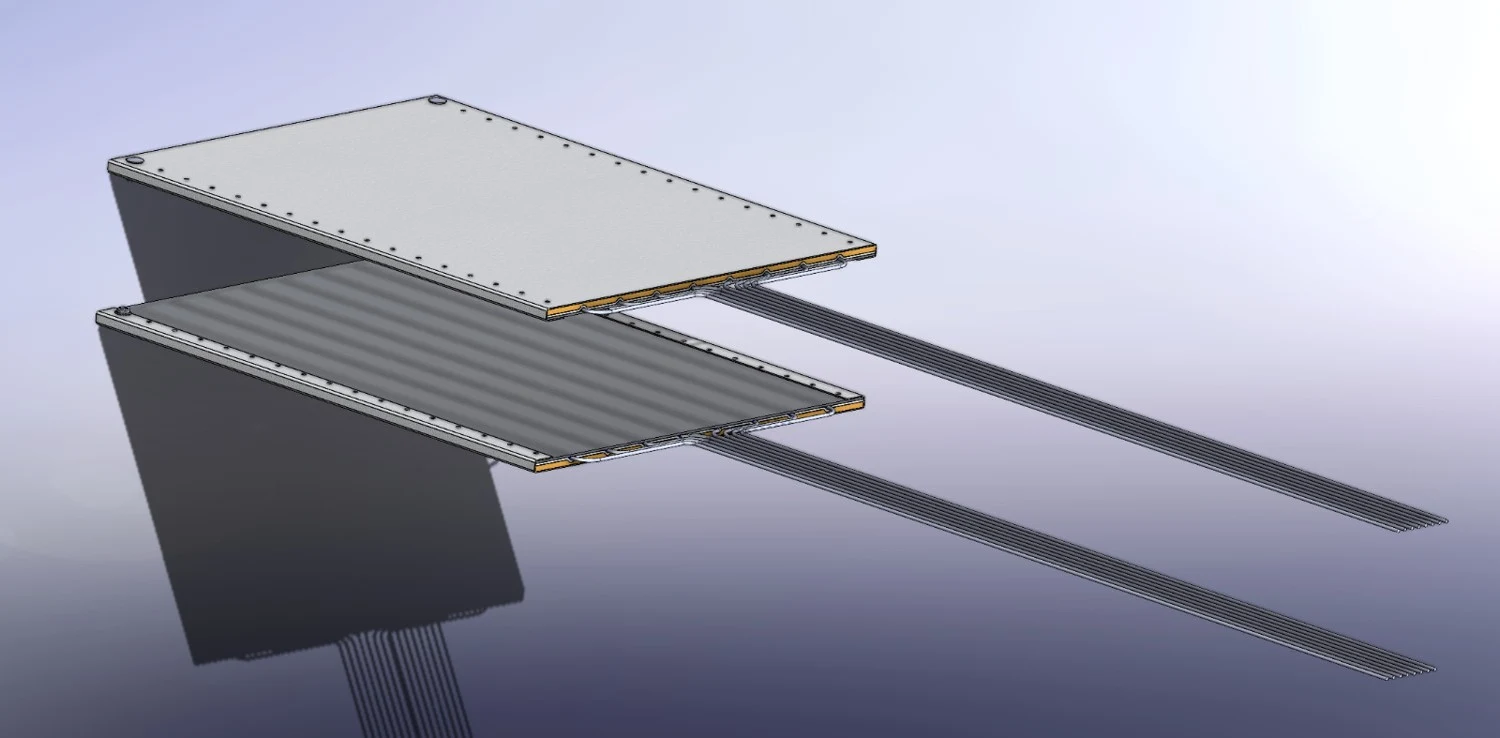
Neonatal phototherapy blanket
A SolidWorks medical-device design study combining fiber-optic light delivery, LED-driver selection, thermal analysis, and optical power budgeting.
Medical and assistive devices project · MME 4470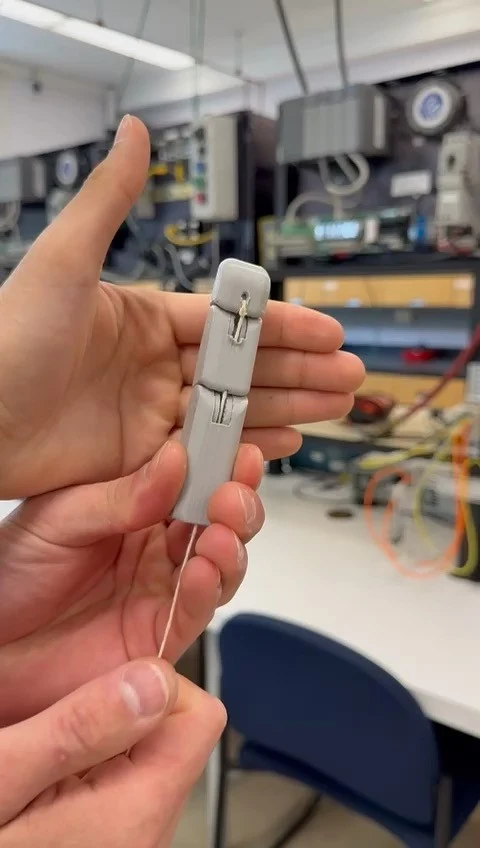
SMA actuation & tendon-driven finger
I connected muscle-signal processing with shape-memory alloy (SMA) actuation and designed a SolidWorks, 3D-printed tendon-driven finger to explore prosthetic movement.
Biosignal processing, actuator circuits and prosthetic mechanism design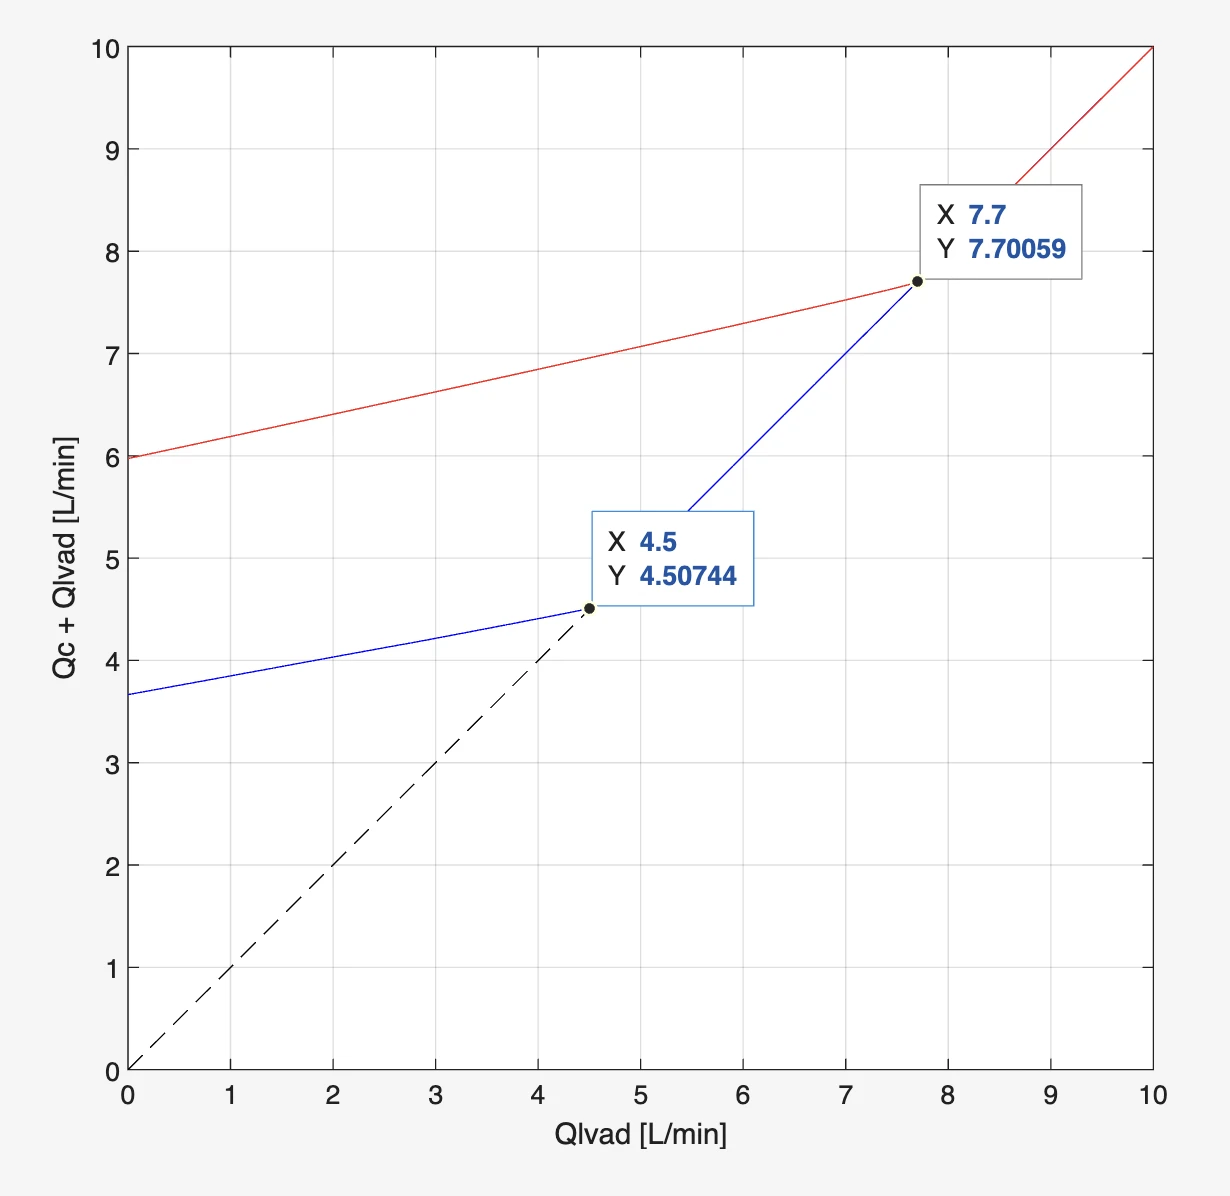
Cardiovascular modeling & cardiac-device simulations
I used MATLAB to investigate two cardiac-device questions: how LVAD support changes circulation, and how biphasic shock timing changes modeled cardiac membrane response.
Cardiovascular simulation and analysis · team project contributionsLeadership & Entrepreneurship
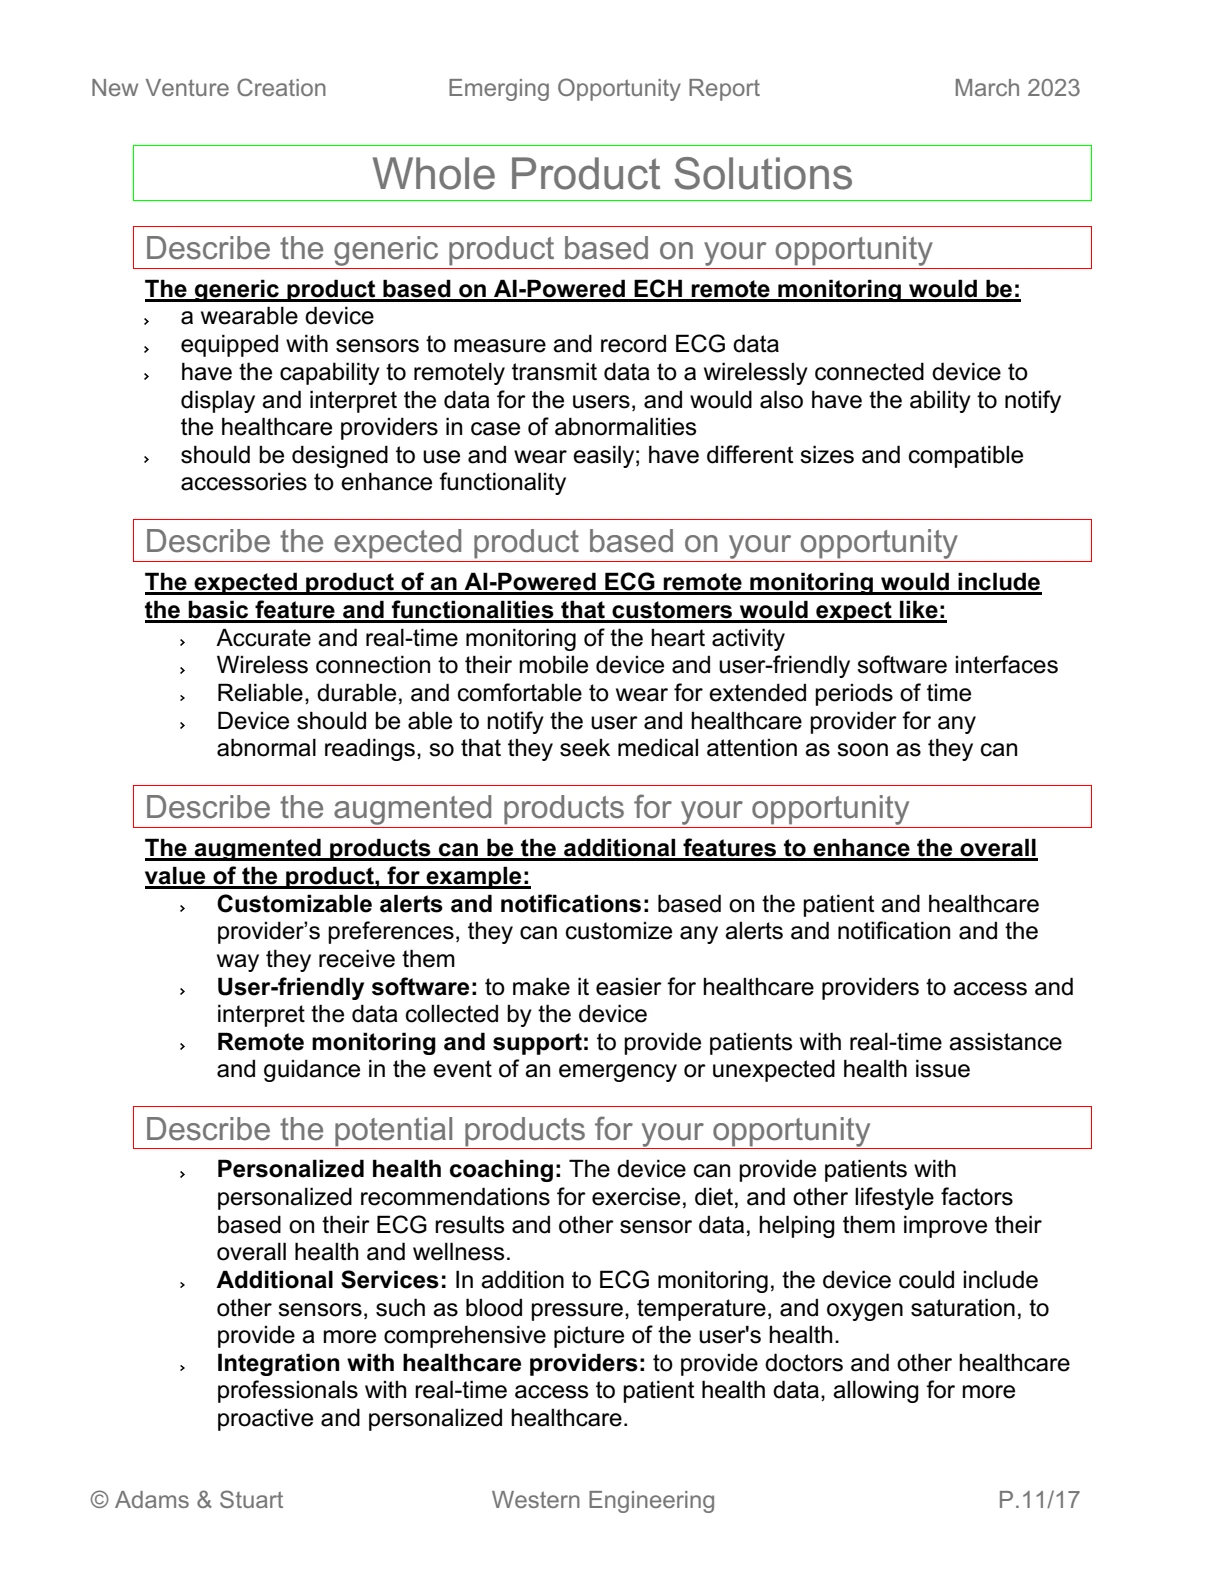
AI-powered ECG wearable venture study
A Lean Canvas and healthcare opportunity study for an AI-enabled ECG wearable, covering users, value proposition, and the proposed product ecosystem.
Engineering entrepreneurship project
FarmerConnect business plan
A FarmerConnect venture plan and PowerPoint pitch supported by a Lean Canvas, market research, and app-interface mockups.
Entrepreneurship project
AutoPicker consulting project
A team consulting presentation applying SWOT and external-market analysis to AutoPicker’s vehicle-service business proposition.
Team consulting project · with Elijah Cook