Sharps Safety Training
KAUST
Research
My current research and my earlier experimental work in soft robotics.
Current research · KAUST
I am researching how cooperative autonomous vehicles can share and combine sensor information reliably when some measurements are faulty or compromised. My work explores how differences between sensors, uncertainty, and unreliable contributions affect cooperation and decision-making across vehicles.
I am reviewing and comparing published approaches to fault diagnosis, robust aggregation, and trust-aware cooperation, and formalizing how these components could fit into an overall system model.
Alongside this, I am defining evaluation plans to study reliability and security, while considering practical communication and computation limits.
Current research · KAUST
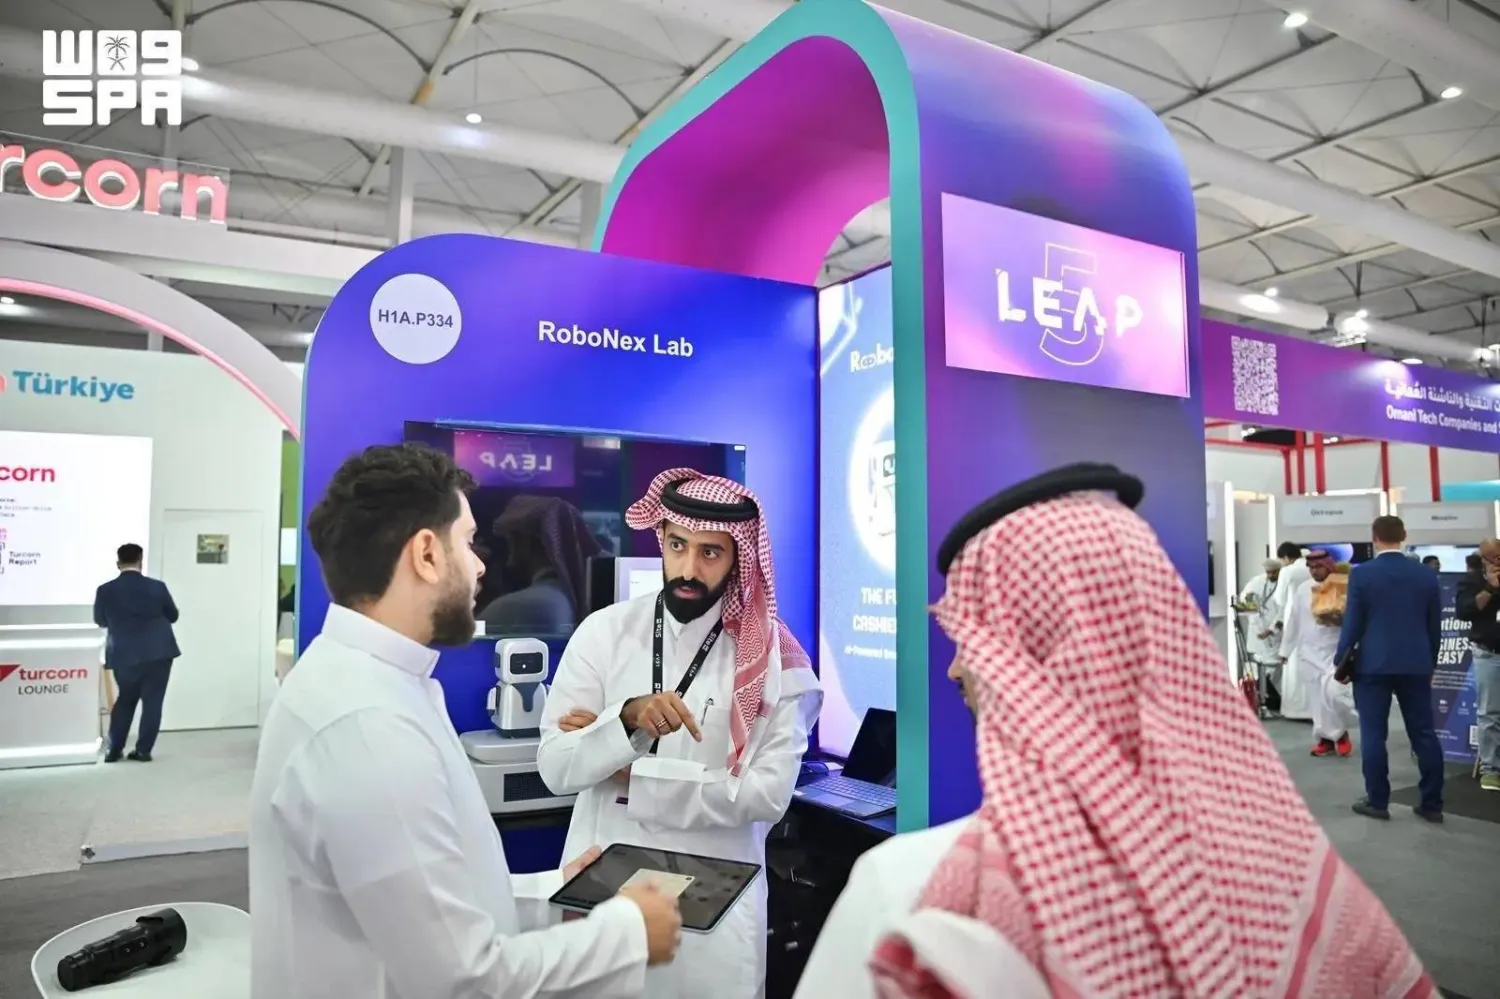
I am working on AI for RoboNex, exploring how a service robot can interpret video, audio and interaction context to understand human behavior and respond appropriately.
My work explores multimodal perception and intent recognition, including how large models can support data preparation and how smaller models could support efficient inference. I am reviewing and comparing approaches for behavior understanding and context-aware robot interaction.
Research internship · 2023
Experimental research on liquid crystal elastomers for soft robotics, from material preparation and fabrication to heat-responsive motion, load testing, and a solar-tracker demonstrator.
Fabrication, material preparation, and experimental testing of responsive polymer actuators.
2023 research & experiments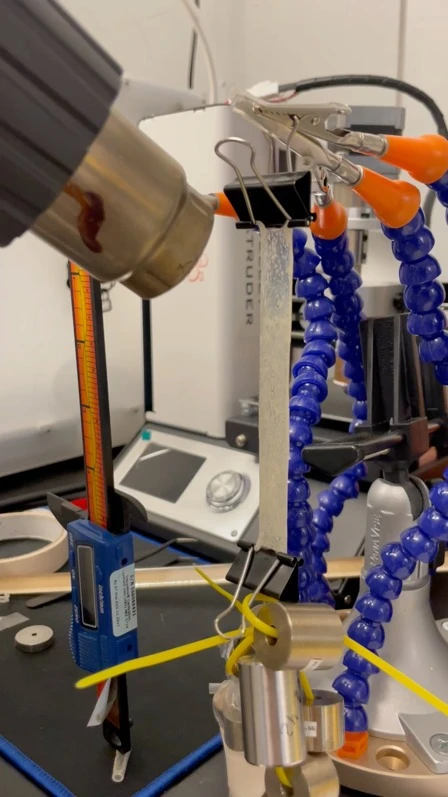
KAUST
Certificates from the 2023 research internship.
KAUST
KAUST · Nanofabrication Core Lab
KAUST
KAUST
KAUST