The task
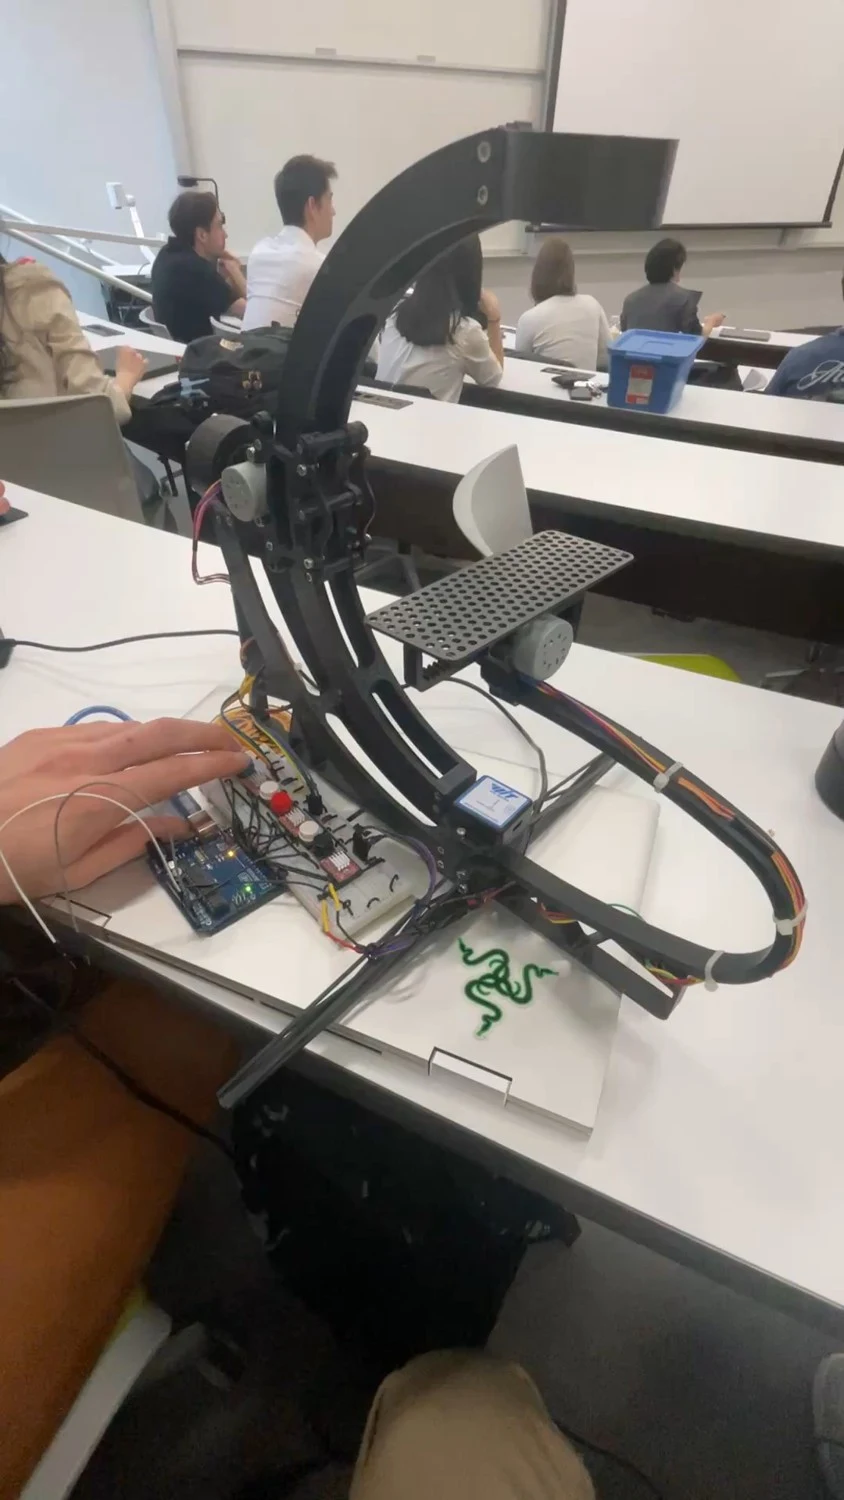
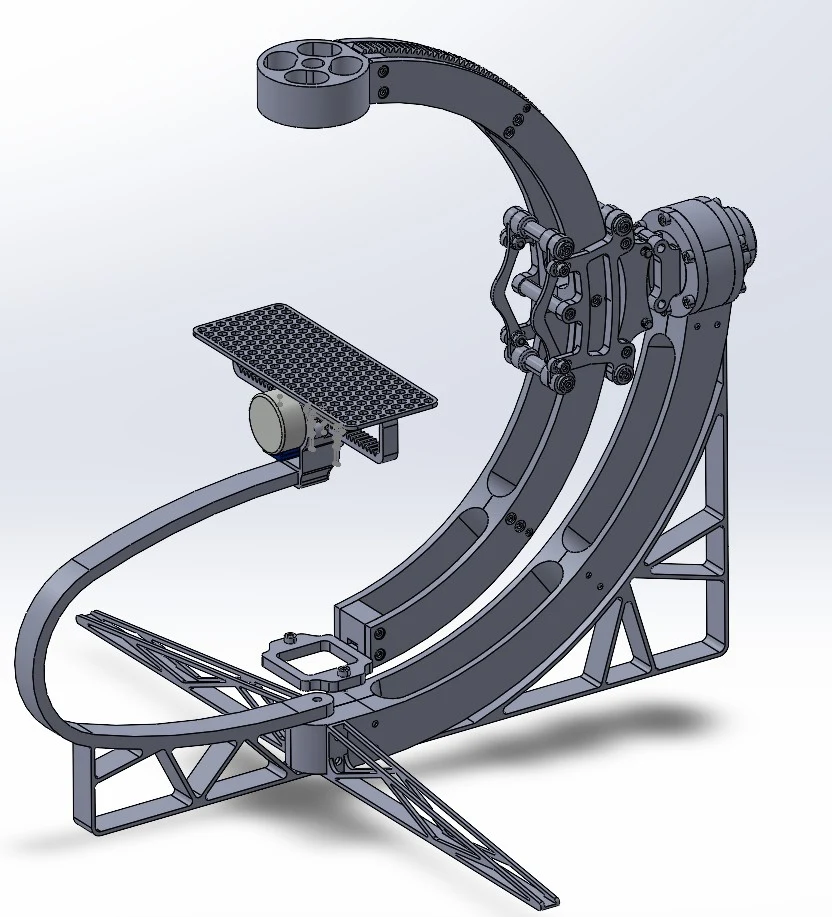
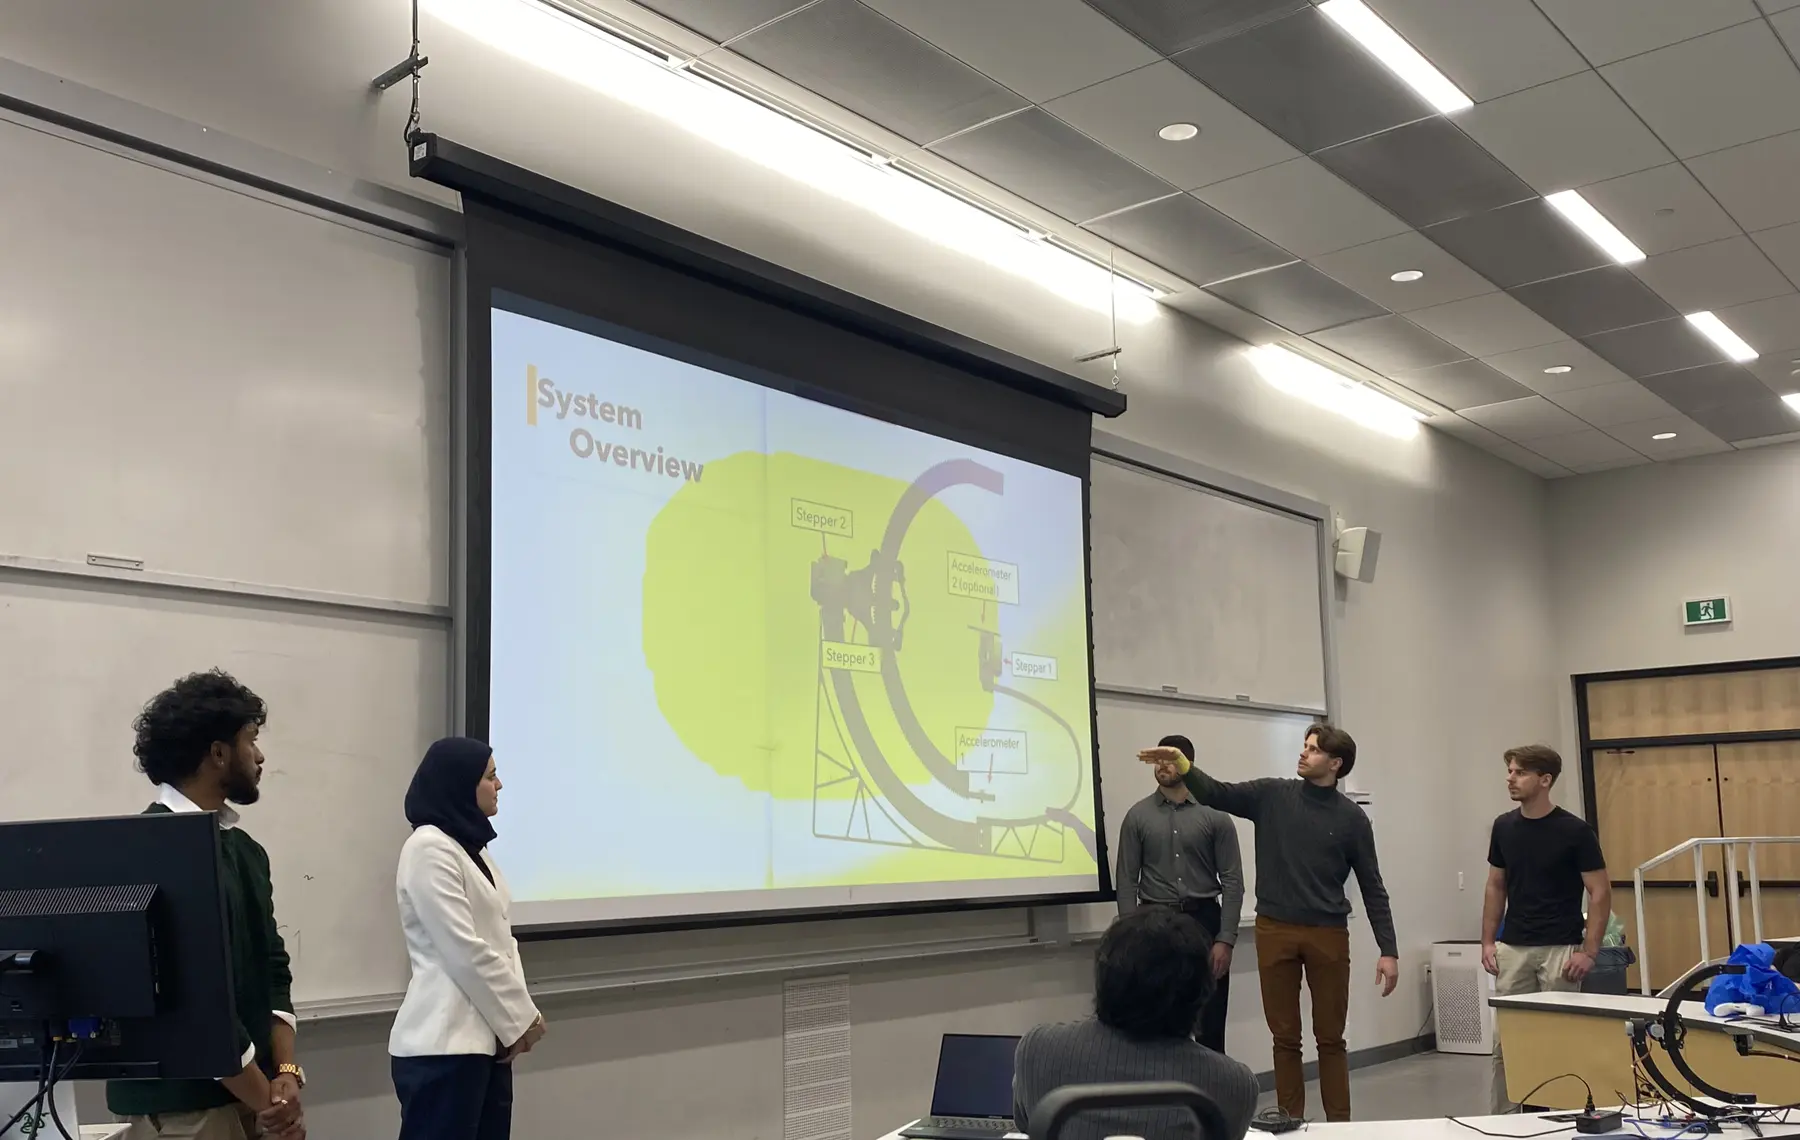
The team designed a miniature C-arm simulator to explore positioning and movement associated with surgical imaging equipment.
The system
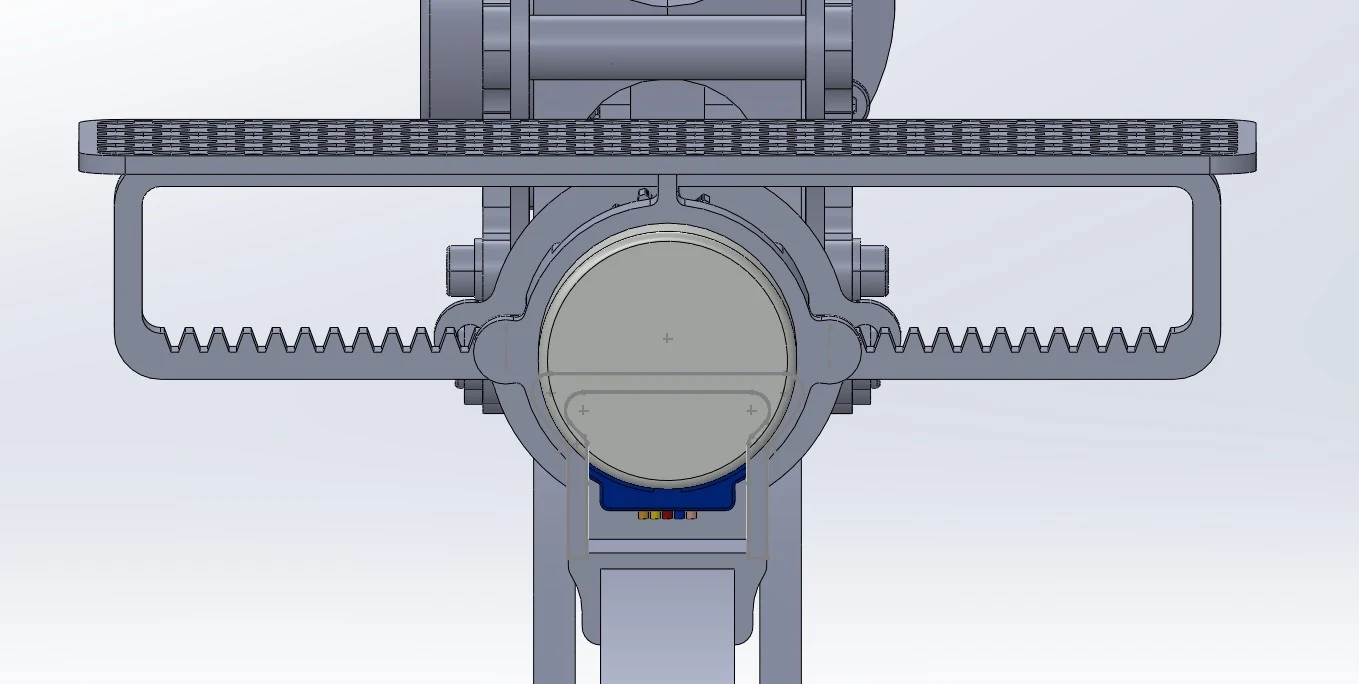
The prototype combined a SolidWorks mechanical design and PLA printed parts with geared stepper motors and Bluetooth orientation sensing. Embedded control connected sensing to mechanical motion.
What it demonstrates
The work shows integration across mechanical design, sensing, actuation, and firmware. It is a training-oriented motion prototype rather than an X-ray imaging system.
Mechanical, embedded and visualization tools
Our team modeled the C-arm and surgical table in SolidWorks and fabricated the mechanism using PLA 3D printing. An Arduino Uno ran Arduino C++ with AccelStepper to control converted 28BYJ-48 motors through A4988 stepper drivers. Pushbuttons commanded translation and rotation; software travel limits and a shared enable line controlled movement and idle power. We worked with Bluetooth orientation sensing and the PLUS Server / 3D Slicer visualization chain. The report also records sensor communication and virtual-motion failures during later testing, so this was an integration prototype with unresolved reliability issues.