The challenge
The course challenge called for a rover that could collect and sort colored gems, then return to base within a time and parts budget.
The design
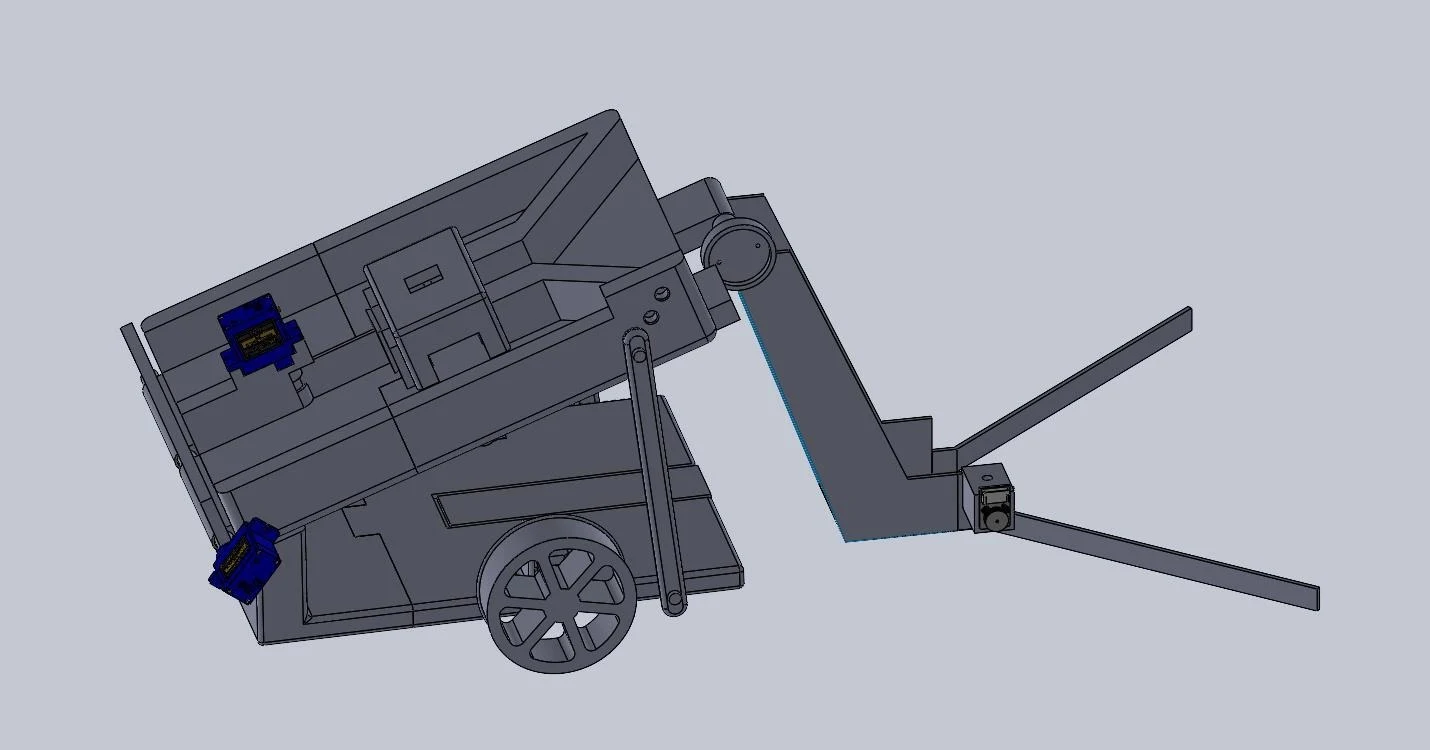
Our team used a funnel and revolving-door sorter with a color sensor inside a light-isolated chamber. ESP32-S3 firmware, encoder feedback, and motor control supported rover movement, while a servo-operated pickup mechanism handled the gems.
Results and limitations
The report describes pickup and color-sorting success, with return-to-base behavior limited by IR-beacon localization. This made sensing reliability and recovery an important part of the final analysis.
Mechanics, sensing and embedded control
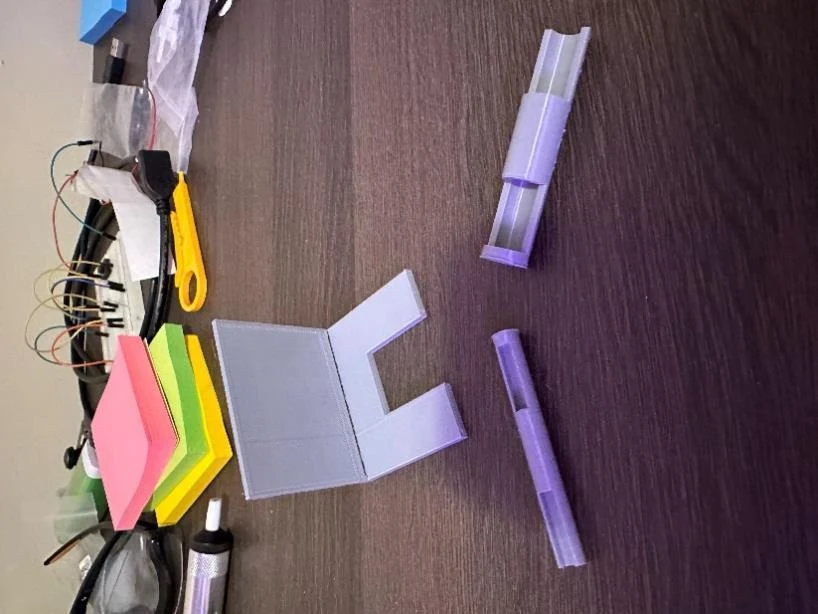
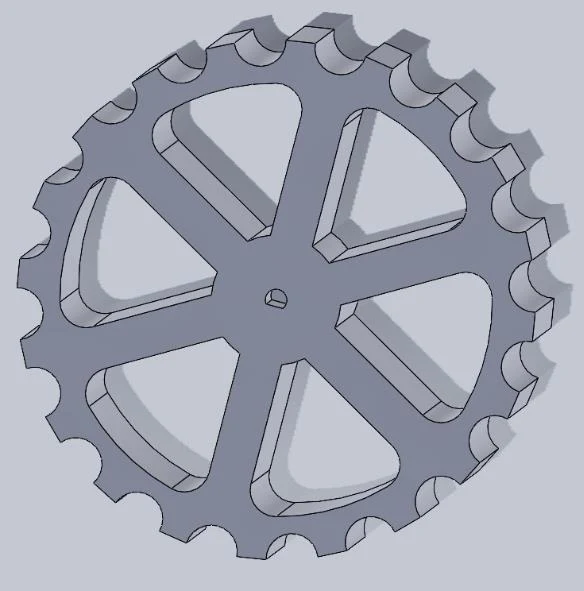
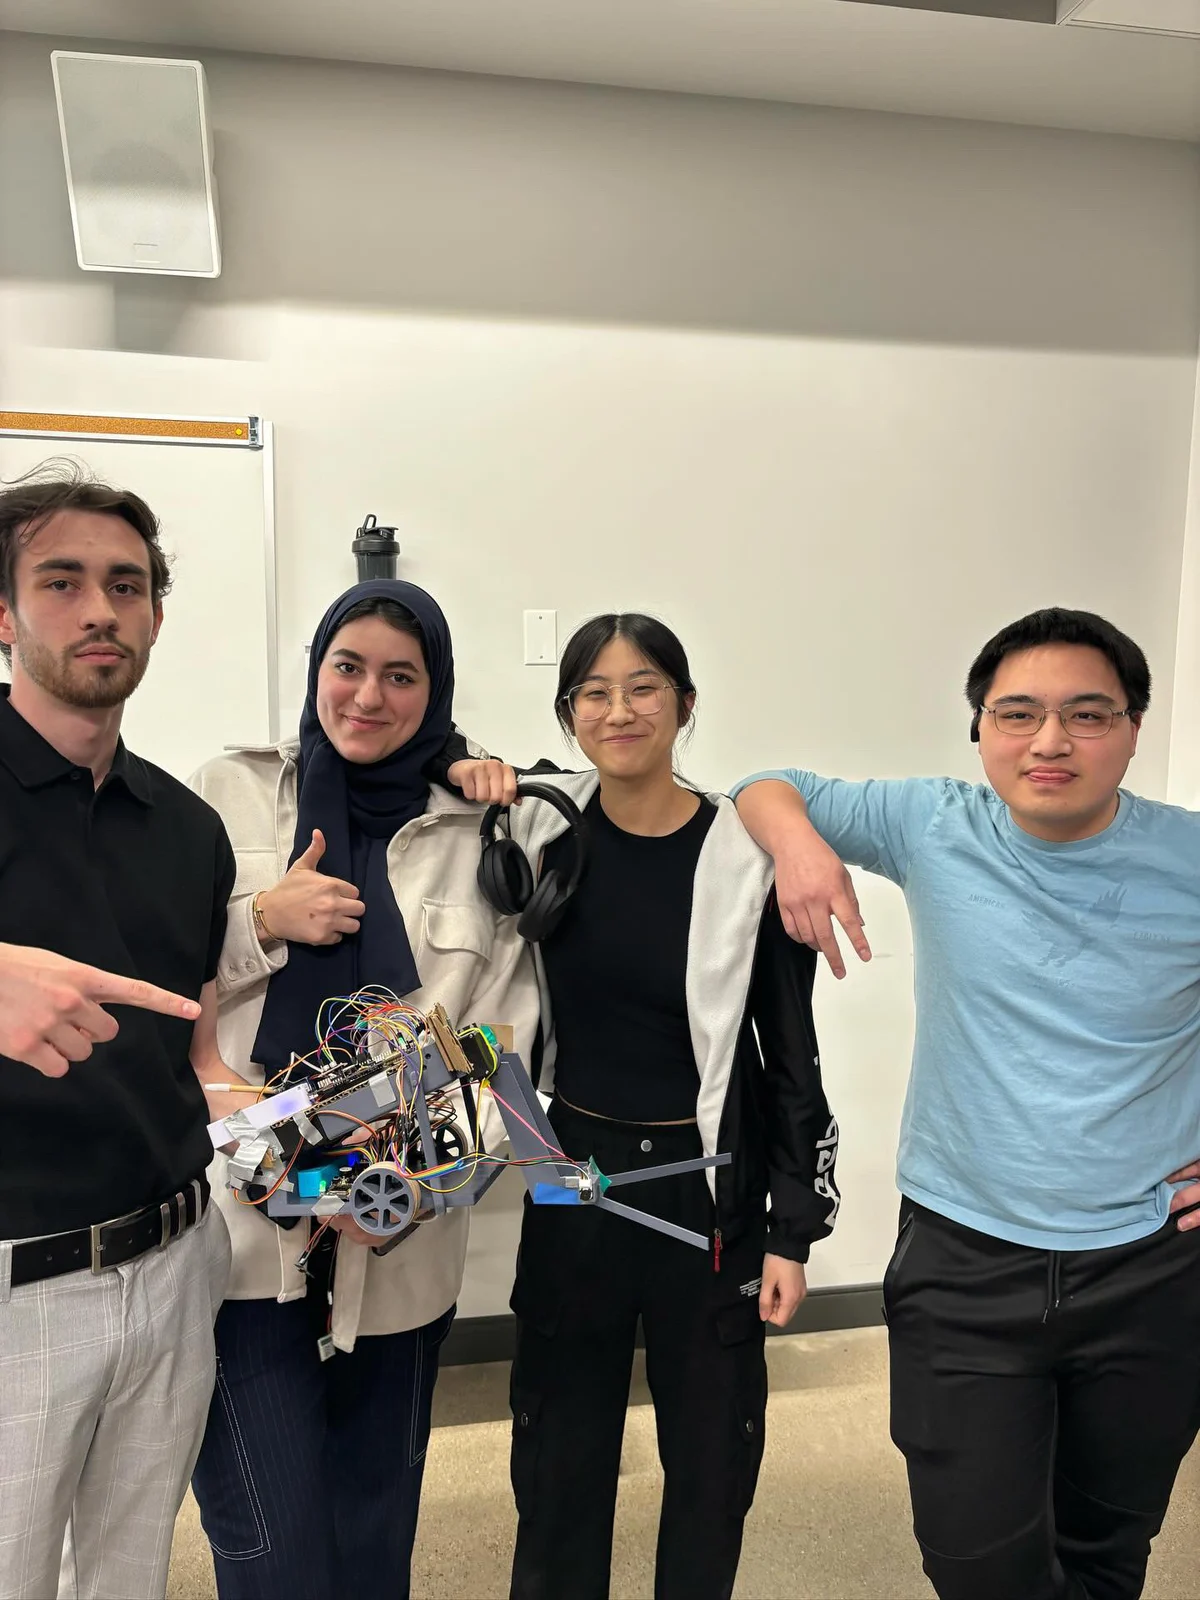
The rover combined SolidWorks-designed and 3D-printed pickup and sorting mechanisms with ESP32-S3 Arduino C++ firmware. The MSE2202 library supported motor control and encoder feedback; PID control addressed wheel positioning. A TCS34725 color sensor distinguished gems inside a light-isolated sorting chamber, with servo-actuated collection and sorting hardware. Infrared-beacon homing and wheel traction were practical limitations during testing. This was a team build spanning mechanical design, sensor integration and embedded control.